Unique Paths II solution and explanation
 Google

9 more videos on this problem
 Unique Paths II - Leetcode 63 - PythonNeetCodeIO · 14:31 · 33K views
 Unique Paths 2 | Dynamic Programming | Leetcode #63Techdose · 16:33 · 27K views
 Unique Paths II | Recursion | Memo | Bottom Up | Leetcode 63 | DP On Grids | codestorywithMIKcodestorywithMIK · 45:42 · 7K views
 Unique Paths II | Made Super Easy | Recursion | Memoization | 2D Array | AMAZON | Leetcode-63codestorywithMIK · 19:44 · 6K views
 Unique Paths II | Live Coding with Explanation | Leetcode - 63Algorithms Made Easy · 12:52 · 4K views
 [Java] Leetcode 63. Unique Paths II [DP Distinct Ways #3]Eric Programming · 14:31 · 1K views
 LEETCODE 63 (JAVASCRIPT) | UNIQUE PATHS II | CODING INTERVIEW PREPAndy Gala · 13:57 · 1K views
 Master Dynamic Programming in 15 Minutes! LeetCode 63. Unique Paths II in PythonvanAmsen · 7:45 · 1K views
 Unique Paths II | Leetcode 63 | Dynamic Programming 🔥🔥🔥 | Easy Peasy | Live coding sessionCoding Decoded · 9:27 · 1K views
 Unique Paths II - LeetCode 63 - JavaScriptAlgoJS · 7:00 · 607 views
The problem
You are given an m x n integer array grid. There is a robot initially located at the top-left corner (i.e., grid[0][0]). The robot tries to move to the bottom-right corner (i.e., grid[m - 1][n - 1]). The robot can only move either down or right at any point in time.
An obstacle and space are marked as 1 or 0 respectively in grid. A path that the robot takes cannot include any square that is an obstacle.
Return the number of possible unique paths that the robot can take to reach the bottom-right corner.
The testcases are generated so that the answer will be less than or equal to 2 * 109.
Example 1:
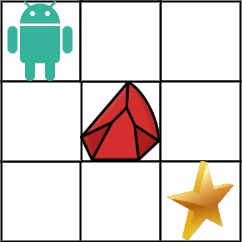
Input: obstacleGrid = [[0,0,0],[0,1,0],[0,0,0]]
Output: 2
Explanation: There is one obstacle in the middle of the 3x3 grid above.
There are two ways to reach the bottom-right corner:
1. Right -> Right -> Down -> Down
2. Down -> Down -> Right -> Right
Example 2:
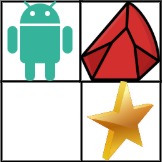
Input: obstacleGrid = [[0,1],[0,0]]
Output: 1
Constraints:
m == obstacleGrid.lengthn == obstacleGrid[i].length1 <= m, n <= 100obstacleGrid[i][j]is0or1.
Approach overview
Problem Overview: Given an m x n grid where some cells contain obstacles, count how many unique paths exist from the top-left corner to the bottom-right corner. You can only move right or down, and any cell marked as an obstacle blocks the path.
Approach 1: Dynamic Programming (O(m*n) time, O(m*n) space)
This approach builds a 2D DP table where dp[i][j] stores the number of ways to reach cell (i, j). If the current cell is not an obstacle, the number of paths equals the sum of paths from the top cell dp[i-1][j] and the left cell dp[i][j-1]. If the cell contains an obstacle, its value becomes 0 because no path can pass through it. You iterate row by row through the matrix, updating the DP table using previously computed values. This approach clearly models the recurrence relation and is the easiest way to reason about the state transitions.
Approach 2: Space Optimized Dynamic Programming (O(m*n) time, O(n) space)
The DP relation only depends on the current row and the previous row, so a full m x n table is unnecessary. Instead, maintain a single array of size n where each element represents the number of ways to reach that column in the current row. While iterating through the grid, update the array in place: if a cell contains an obstacle, set the value to 0; otherwise add the value from the left neighbor dp[j] += dp[j-1]. This technique reduces memory usage while preserving the same recurrence used in dynamic programming. The logic still processes the grid row by row using standard array iteration.
Recommended for interviews: The standard 2D dynamic programming solution demonstrates clear understanding of the recurrence and boundary conditions, so it is the safest explanation during interviews. After presenting it, optimizing to a single-row DP array shows deeper understanding of memory optimization and DP state compression.
Approach 1: Dynamic Programming Approach
Using dynamic programming, we can track the number of unique paths to each cell in the grid. Initialize a DP matrix of the same dimensions as the grid. If a cell contains an obstacle (value of 1), it will have 0 paths. Start from the top-left corner and accumulate the number of paths by adding the values from the cell above and the cell to the left, if they exist, taking into account obstacles.
def uniquePathsWithObstacles(obstacleGrid):
    m, n = len(obstacleGrid), len(obstacleGrid[0])
    dp = [[0] * n for _ in range(m)]

    for i in range(m):
        for j in range(n):
            if obstacleGrid[i][j] == 1:
                dp[i][j] = 0
            elif i == 0 and j == 0:
                dp[i][j] = 1
            else:
                dp[i][j] = (dp[i-1][j] if i > 0 else 0) + (dp[i][j-1] if j > 0 else 0)

return dp[-1][-1]class Solution {
public int uniquePathsWithObstacles(int[][] obstacleGrid) {
int m = obstacleGrid.length;
int n = obstacleGrid[0].length;
int[][] dp = new int[m][n];
for (int i = 0; i < m; i++) {
for (int j = 0; j < n; j++) {
if (obstacleGrid[i][j] == 1) {
dp[i][j] = 0;
} else if (i == 0 && j == 0) {
dp[i][j] = 1;
} else {
dp[i][j] = (i > 0 ? dp[i-1][j] : 0) + (j > 0 ? dp[i][j-1] : 0);
}
}
}
return dp[m - 1][n - 1];
}
}#include <vector>
using namespace std;
int uniquePathsWithObstacles(vector<vector<int>>& obstacleGrid) {
int m = obstacleGrid.size();
int n = obstacleGrid[0].size();
vector<vector<int>> dp(m, vector<int>(n, 0));
for (int i = 0; i < m; ++i) {
for (int j = 0; j < n; ++j) {
if (obstacleGrid[i][j] == 1) {
dp[i][j] = 0;
} else if (i == 0 && j == 0) {
dp[i][j] = 1;
} else {
dp[i][j] = (i > 0 ? dp[i-1][j] : 0) + (j > 0 ? dp[i][j-1] : 0);
}
}
}
return dp[m-1][n-1];
}var uniquePathsWithObstacles = function(obstacleGrid) {
let m = obstacleGrid.length;
let n = obstacleGrid[0].length;
let dp = Array.from({length: m}, () => Array(n).fill(0));
for (let i = 0; i < m; i++) {
for (let j = 0; j < n; j++) {
if (obstacleGrid[i][j] === 1) {
dp[i][j] = 0;
} else if (i === 0 && j === 0) {
dp[i][j] = 1;
} else {
dp[i][j] = (i > 0 ? dp[i-1][j] : 0) + (j > 0 ? dp[i][j-1] : 0);
}
}
}
return dp[m-1][n-1];
};#include <stdio.h>
int uniquePathsWithObstacles(int** obstacleGrid, int m, int n) {
int dp[m][n];
// Initialize DP table
for (int i = 0; i < m; i++) {
for (int j = 0; j < n; j++) {
if (obstacleGrid[i][j] == 1) {
dp[i][j] = 0;
} else if (i == 0 && j == 0) {
dp[i][j] = 1;
} else if (i == 0) {
dp[i][j] = dp[i][j - 1];
} else if (j == 0) {
dp[i][j] = dp[i - 1][j];
} else {
dp[i][j] = dp[i - 1][j] + dp[i][j - 1];
}
}
}
return dp[m - 1][n - 1];
}public class Solution {
public int UniquePathsWithObstacles(int[][] obstacleGrid) {
int m = obstacleGrid.Length;
int n = obstacleGrid[0].Length;
int[,] dp = new int[m, n];
for (int i = 0; i < m; i++) {
for (int j = 0; j < n; j++) {
if (obstacleGrid[i][j] == 1) {
dp[i, j] = 0;
} else if (i == 0 && j == 0) {
dp[i, j] = 1;
} else {
dp[i, j] = (i > 0 ? dp[i-1, j] : 0) + (j > 0 ? dp[i, j-1] : 0);
}
}
}
return dp[m - 1, n - 1];
}
}Python solution creates a DP matrix to calculate unique paths considering obstacles, starting from the first cell and iteratively processing each cell's possible paths.
Time Complexity: O(m * n), as we iterate through entire grid.
Space Complexity: O(m * n), due to the use of dp table.
Approach 2: Space Optimized Dynamic Programming
Instead of using a full 2D DP array, we can optimize space by maintaining just a single row of size `n` to hold the number of paths to positions in the current row. Iterate over the grid, and update path counts by only storing the results for the current row, using the previous row information to calculate paths.
def uniquePathsWithObstacles(obstacleGrid):
    m, n = len(obstacleGrid), len(obstacleGrid[0])
    dp = [0] * n
    dp[0] = 1 if obstacleGrid[0][0] == 0 else 0

    for i in range(m):
        for j in range(n):
            if obstacleGrid[i][j] == 1:
                dp[j] = 0
            elif j > 0:
                dp[j] += dp[j - 1]
return dp[-1]class Solution {
public int uniquePathsWithObstacles(int[][] obstacleGrid) {
int m = obstacleGrid.length;
int n = obstacleGrid[0].length;
int[] dp = new int[n];
dp[0] = obstacleGrid[0][0] == 0 ? 1 : 0;
for (int i = 0; i < m; i++) {
for (int j = 0; j < n; j++) {
if (obstacleGrid[i][j] == 1) {
dp[j] = 0;
} else if (j > 0) {
dp[j] += dp[j - 1];
}
}
}
return dp[n - 1];
}
}#include <vector>
using namespace std;
int uniquePathsWithObstacles(vector<vector<int>>& obstacleGrid) {
int m = obstacleGrid.size();
int n = obstacleGrid[0].size();
vector<int> dp(n, 0);
dp[0] = obstacleGrid[0][0] == 0 ? 1 : 0;
for (int i = 0; i < m; ++i) {
for (int j = 0; j < n; ++j) {
if (obstacleGrid[i][j] == 1) {
dp[j] = 0;
} else if (j > 0) {
dp[j] += dp[j - 1];
}
}
}
return dp[n - 1];
}var uniquePathsWithObstacles = function(obstacleGrid) {
let m = obstacleGrid.length;
let n = obstacleGrid[0].length;
let dp = Array(n).fill(0);
dp[0] = obstacleGrid[0][0] === 0 ? 1 : 0;
for (let i = 0; i < m; i++) {
for (let j = 0; j < n; j++) {
if (obstacleGrid[i][j] === 1) {
dp[j] = 0;
} else if (j > 0) {
dp[j] += dp[j - 1];
}
}
}
return dp[n - 1];
};#include <stdio.h>
int uniquePathsWithObstacles(int** obstacleGrid, int m, int n) {
int dp[n];
memset(dp, 0, sizeof(dp));
dp[0] = obstacleGrid[0][0] == 0 ? 1 : 0;
for (int i = 0; i < m; i++) {
for (int j = 0; j < n; j++) {
if (obstacleGrid[i][j] == 1) {
dp[j] = 0;
} else if (j > 0) {
dp[j] += dp[j - 1];
}
}
}
return dp[n - 1];
}public class Solution {
public int UniquePathsWithObstacles(int[][] obstacleGrid) {
int m = obstacleGrid.Length;
int n = obstacleGrid[0].Length;
int[] dp = new int[n];
dp[0] = obstacleGrid[0][0] == 0 ? 1 : 0;
for (int i = 0; i < m; i++) {
for (int j = 0; j < n; j++) {
if (obstacleGrid[i][j] == 1) {
dp[j] = 0;
} else if (j > 0) {
dp[j] += dp[j - 1];
}
}
}
return dp[n - 1];
}
}Python solution applies space optimization by limiting storage to a single array retaining path counts, efficiently managing obstacle-negotiated computations.
Time Complexity: O(m * n), iterating over all grid cells.
Space Complexity: O(n), single-dimensional path tracking per row.
Approach 3: Memoization Search
We design a function dfs(i, j) to represent the number of paths from the grid (i, j) to the grid (m - 1, n - 1). Here, m and n are the number of rows and columns of the grid, respectively.
The execution process of the function dfs(i, j) is as follows:
- If
i \ge morj \ge n, orobstacleGrid[i][j] = 1, the number of paths is0; - If
i = m - 1andj = n - 1, the number of paths is1; - Otherwise, the number of paths is
dfs(i + 1, j) + dfs(i, j + 1).
To avoid redundant calculations, we can use memoization.
The time complexity is O(m times n), and the space complexity is O(m times n). Here, m and n are the number of rows and columns of the grid, respectively.
function uniquePathsWithObstacles(obstacleGrid: number[][]): number {
    const m = obstacleGrid.length;
    const n = obstacleGrid[0].length;
    const f: number[][] = Array.from({ length: m }, () => Array(n).fill(-1));
    const dfs = (i: number, j: number): number => {
        if (i >= m || j >= n || obstacleGrid[i][j] === 1) {
            return 0;
        }
        if (i === m - 1 && j === n - 1) {
            return 1;
        }
        if (f[i][j] === -1) {
            f[i][j] = dfs(i + 1, j) + dfs(i, j + 1);
        }
        return f[i][j];
    };
    return dfs(0, 0);
}func uniquePathsWithObstacles(obstacleGrid [][]int) int {
m, n := len(obstacleGrid), len(obstacleGrid[0])
f := make([][]int, m)
for i := range f {
f[i] = make([]int, n)
for j := range f[i] {
f[i][j] = -1
}
}
var dfs func(i, j int) int
dfs = func(i, j int) int {
if i >= m || j >= n || obstacleGrid[i][j] == 1 {
return 0
}
if i == m-1 && j == n-1 {
return 1
}
if f[i][j] == -1 {
f[i][j] = dfs(i+1, j) + dfs(i, j+1)
}
return f[i][j]
}
return dfs(0, 0)
}impl Solution {
pub fn unique_paths_with_obstacles(obstacle_grid: Vec<Vec<i32>>) -> i32 {
let m = obstacle_grid.len();
let n = obstacle_grid[0].len();
let mut f = vec![vec![-1; n]; m];
Self::dfs(0, 0, &obstacle_grid, &mut f)
}
fn dfs(i: usize, j: usize, obstacle_grid: &Vec<Vec<i32>>, f: &mut Vec<Vec<i32>>) -> i32 {
let m = obstacle_grid.len();
let n = obstacle_grid[0].len();
if i >= m || j >= n || obstacle_grid[i][j] == 1 {
return 0;
}
if i == m - 1 && j == n - 1 {
return 1;
}
if f[i][j] != -1 {
return f[i][j];
}
let down = Self::dfs(i + 1, j, obstacle_grid, f);
let right = Self::dfs(i, j + 1, obstacle_grid, f);
f[i][j] = down + right;
f[i][j]
}
}Approach 4: Dynamic Programming
We can use a dynamic programming approach by defining a 2D array f, where f[i][j] represents the number of paths from the grid (0,0) to the grid (i,j).
We first initialize all values in the first column and the first row of f, then traverse the other rows and columns with two cases:
- If
obstacleGrid[i][j] = 1, it means the number of paths is0, sof[i][j] = 0; - If
obstacleGrid[i][j] = 0, thenf[i][j] = f[i - 1][j] + f[i][j - 1].
Finally, return f[m - 1][n - 1].
The time complexity is O(m times n), and the space complexity is O(m times n). Here, m and n are the number of rows and columns of the grid, respectively.
function uniquePathsWithObstacles(obstacleGrid: number[][]): number {
    const m = obstacleGrid.length;
    const n = obstacleGrid[0].length;
    const f = Array.from({ length: m }, () => Array(n).fill(0));
    for (let i = 0; i < m; i++) {
        if (obstacleGrid[i][0] === 1) {
            break;
        }
        f[i][0] = 1;
    }
    for (let i = 0; i < n; i++) {
        if (obstacleGrid[0][i] === 1) {
            break;
        }
        f[0][i] = 1;
    }
    for (let i = 1; i < m; i++) {
        for (let j = 1; j < n; j++) {
            if (obstacleGrid[i][j] === 1) {
                continue;
            }
            f[i][j] = f[i - 1][j] + f[i][j - 1];
        }
    }
    return f[m - 1][n - 1];
}func uniquePathsWithObstacles(obstacleGrid [][]int) int {
m, n := len(obstacleGrid), len(obstacleGrid[0])
f := make([][]int, m)
for i := 0; i < m; i++ {
f[i] = make([]int, n)
}
for i := 0; i < m && obstacleGrid[i][0] == 0; i++ {
f[i][0] = 1
}
for j := 0; j < n && obstacleGrid[0][j] == 0; j++ {
f[0][j] = 1
}
for i := 1; i < m; i++ {
for j := 1; j < n; j++ {
if obstacleGrid[i][j] == 0 {
f[i][j] = f[i-1][j] + f[i][j-1]
}
}
}
return f[m-1][n-1]
}impl Solution {
pub fn unique_paths_with_obstacles(obstacle_grid: Vec<Vec<i32>>) -> i32 {
let m = obstacle_grid.len();
let n = obstacle_grid[0].len();
let mut f = vec![vec![0; n]; m];
for i in 0..n {
if obstacle_grid[0][i] == 1 {
break;
}
f[0][i] = 1;
}
for i in 0..m {
if obstacle_grid[i][0] == 1 {
break;
}
f[i][0] = 1;
}
for i in 1..m {
for j in 1..n {
if obstacle_grid[i][j] == 1 {
continue;
}
f[i][j] = f[i - 1][j] + f[i][j - 1];
}
}
f[m - 1][n - 1]
}
}Complexity comparison
| Approach | Complexity |
|---|---|
| Dynamic Programming Approach | Time Complexity: O(m * n), as we iterate through entire grid. |
| Space Optimized Dynamic Programming | Time Complexity: O(m * n), iterating over all grid cells. |
| Memoization Search | – |
| Dynamic Programming | – |
Complexity analysis
| Approach | Time | Space | When to Use |
|---|---|---|---|
| Dynamic Programming (2D DP Table) | O(m*n) | O(m*n) | Best for clarity when explaining DP state transitions during interviews |
| Space Optimized Dynamic Programming | O(m*n) | O(n) | When memory matters or when demonstrating DP state compression |
Frequently asked questions
Is Unique Paths II easy or hard?
Unique Paths II is considered a medium-level problem. The base Unique Paths problem is easier, but adding obstacles requires careful DP initialization and handling blocked cells during transitions.
How to solve Unique Paths II in O(n) space?
Use a single row DP array of length n. While iterating through each row, update dp[j] based on dp[j] (top) and dp[j-1] (left). If the current cell is an obstacle, reset dp[j] to 0. This keeps the time complexity O(m*n) while reducing memory to O(n).
What is the best approach for Unique Paths II?
Dynamic Programming is the most reliable approach. Create a DP grid where each cell stores the number of ways to reach that position while skipping obstacle cells. The transition adds paths from the top and left neighbors. This runs in O(m*n) time and is the expected interview solution.
What data structure is used in Unique Paths II?
The solution mainly uses arrays to build a dynamic programming table. Either a 2D array stores paths for every grid cell or a 1D array compresses the DP state to reduce space while iterating through the matrix.
What is the time complexity of Unique Paths II?
The standard dynamic programming solution runs in O(m*n) time because each cell of the grid is processed exactly once. The space complexity is O(m*n) for the full DP table or O(n) when using the space-optimized DP array.
Unique Paths II Python or Java solution approach?
Both Python and Java implementations follow the same DP recurrence. Create a DP array, initialize the start cell if it is not an obstacle, and iterate through the grid updating values using paths from the top and left cells. Time complexity remains O(m*n).
Is Unique Paths II asked at Google, Amazon, or Meta interviews?
Grid dynamic programming problems similar to Unique Paths II frequently appear in interviews at companies like Amazon, Google, and Meta. Interviewers use them to test DP reasoning, handling obstacles, and understanding of state transitions in matrix traversal problems.