
Minimum Time for K Connected Components - Solution & Explanation
Problem Statement
You are given an integer n and an undirected graph with n nodes labeled from 0 to n - 1. This is represented by a 2D array edges, where edges[i] = [ui, vi, timei] indicates an undirected edge between nodes ui and vi that can be removed at timei.
You are also given an integer k.
Initially, the graph may be connected or disconnected. Your task is to find the minimum time t such that after removing all edges with time <= t, the graph contains at least k connected components.
Return the minimum time t.
A connected component is a subgraph of a graph in which there exists a path between any two vertices, and no vertex of the subgraph shares an edge with a vertex outside of the subgraph.
Example 1:
Input: n = 2, edges = [[0,1,3]], k = 2
Output: 3
Explanation:
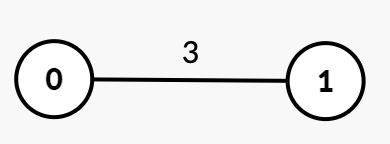
- Initially, there is one connected component
{0, 1}. - At
time = 1or2, the graph remains unchanged. - At
time = 3, edge[0, 1]is removed, resulting ink = 2connected components{0},{1}. Thus, the answer is 3.
Example 2:
Input: n = 3, edges = [[0,1,2],[1,2,4]], k = 3
Output: 4
Explanation:
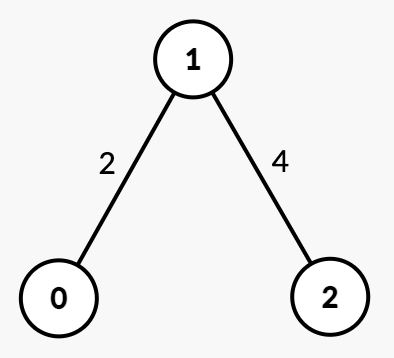
- Initially, there is one connected component
{0, 1, 2}. - At
time = 2, edge[0, 1]is removed, resulting in two connected components{0},{1, 2}. - At
time = 4, edge[1, 2]is removed, resulting ink = 3connected components{0},{1},{2}. Thus, the answer is 4.
Example 3:
Input: n = 3, edges = [[0,2,5]], k = 2
Output: 0
Explanation:
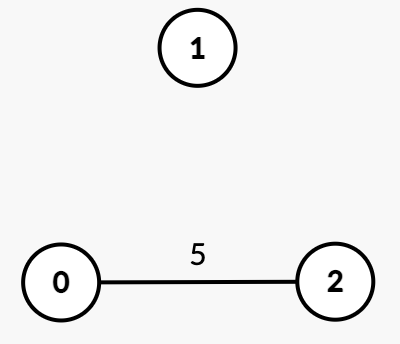
- Since there are already
k = 2disconnected components{1},{0, 2}, no edge removal is needed. Thus, the answer is 0.
Constraints:
1 <= n <= 1050 <= edges.length <= 105edges[i] = [ui, vi, timei]0 <= ui, vi < nui != vi1 <= timei <= 1091 <= k <= n- There are no duplicate edges.
Approach Overview
Problem Overview: You are given connections between nodes that become available at specific times. The goal is to determine the earliest time when the graph forms k or fewer connected components. Edges effectively “activate” over time, so the task becomes identifying the minimum timestamp where enough edges exist to merge components down to k.
Approach 1: Sort Edges + Union-Find Sweep (O(E log E) time, O(N) space)
Sort all edges by their activation time. Start with n components where every node is its own set. Process edges in increasing time order and merge endpoints using a Disjoint Set Union structure. Each successful union reduces the component count by one. As soon as the number of components becomes <= k, the current edge time is the answer.
The key idea mirrors Kruskal’s algorithm: edges added earlier merge components earlier. Union-Find keeps merges efficient with path compression and union by rank. This approach performs a single pass after sorting and works well when the earliest valid time occurs early in the edge list. See related concepts in Union Find and Graph algorithms.
Approach 2: Binary Search on Time + Union-Find Check (O(E log E + E log T) time, O(N) space)
Instead of scanning edges once, treat time as the search space. Sort edges by time and perform Binary Search over the possible timestamps. For a candidate time t, build components using only edges whose time is <= t. Count the resulting components with Union-Find.
If the component count is <= k, the time works and you search earlier times. Otherwise, you need more edges, so search later times. The feasibility check is monotonic: once a time produces at most k components, all larger times will also satisfy the condition. This monotonic property makes binary search valid.
This approach is useful when the time range is large or when the solution pattern matches “minimum time to satisfy a condition.” Each check rebuilds connectivity using Union-Find, keeping operations close to constant time due to path compression.
Recommended for interviews: The Union-Find sweep after sorting edges is the cleanest solution and easiest to reason about. It directly tracks component merges and stops once the count reaches k. Binary search with Union-Find demonstrates stronger algorithmic pattern recognition and is commonly expected when problems involve “minimum time” or monotonic feasibility checks.
Solution
We can sort the edges by time in ascending order, then starting from the edge with the largest time, add edges to the graph one by one, while using a union-find data structure to maintain the number of connected components in the current graph. When the number of connected components is less than k, the current time is the minimum time we are looking for.
The time complexity is O(n times \alpha(n)), and the space complexity is O(n), where \alpha is the inverse Ackermann function.
Code
Python
Java
C++
Go
TypeScript
Detailed Complexity Analysis
| Approach | Time | Space | When to Use |
|---|---|---|---|
| Sort Edges + Union-Find Sweep | O(E log E) | O(N) | Best general solution when edges have timestamps and you only need the earliest merge point |
| Binary Search on Time + Union-Find | O(E log E + E log T) | O(N) | Useful when solving minimum/earliest time feasibility problems with monotonic conditions |
Video Solution
Leetcode 3608 | Minimum time for k connected components | Leetcode weekly context 457 • CodeWithMeGuys • 449 views views
Watch 4 more video solutions →Frequently Asked Questions
Is Minimum Time for K Connected Components easy or hard?
Minimum Time for K Connected Components Python/Java solution
How to solve Minimum Time for K Connected Components in O(E log E)?
What is the best approach for Minimum Time for K Connected Components?
Is Minimum Time for K Connected Components asked at Google/Amazon/Meta?
What data structure is used in Minimum Time for K Connected Components?
What is the time complexity of Minimum Time for K Connected Components?
Ready to solve this problem?
Practice Minimum Time for K Connected Components with our built-in code editor and test cases.
Practice on FleetCodeTable of Contents
Practice this problem
Open in Editor